
How a Stanford student turned muscles, MRI scans and brain signals into a computer model of human movement
Do you know that the human arm, moved by dozens of muscles, has more than 100 dimensions of movement?
Do you know what makes a robotic arm move?
Do you know which academic subjects matter most if you want to build a robot?
When I sat down to interview Toki Migimatsu (右松孝齊), a PhD student in computer science at Stanford University, I was amazed to learn that the human arm involves more than 100 dimensions of movement, and that Toki had managed to model them all.
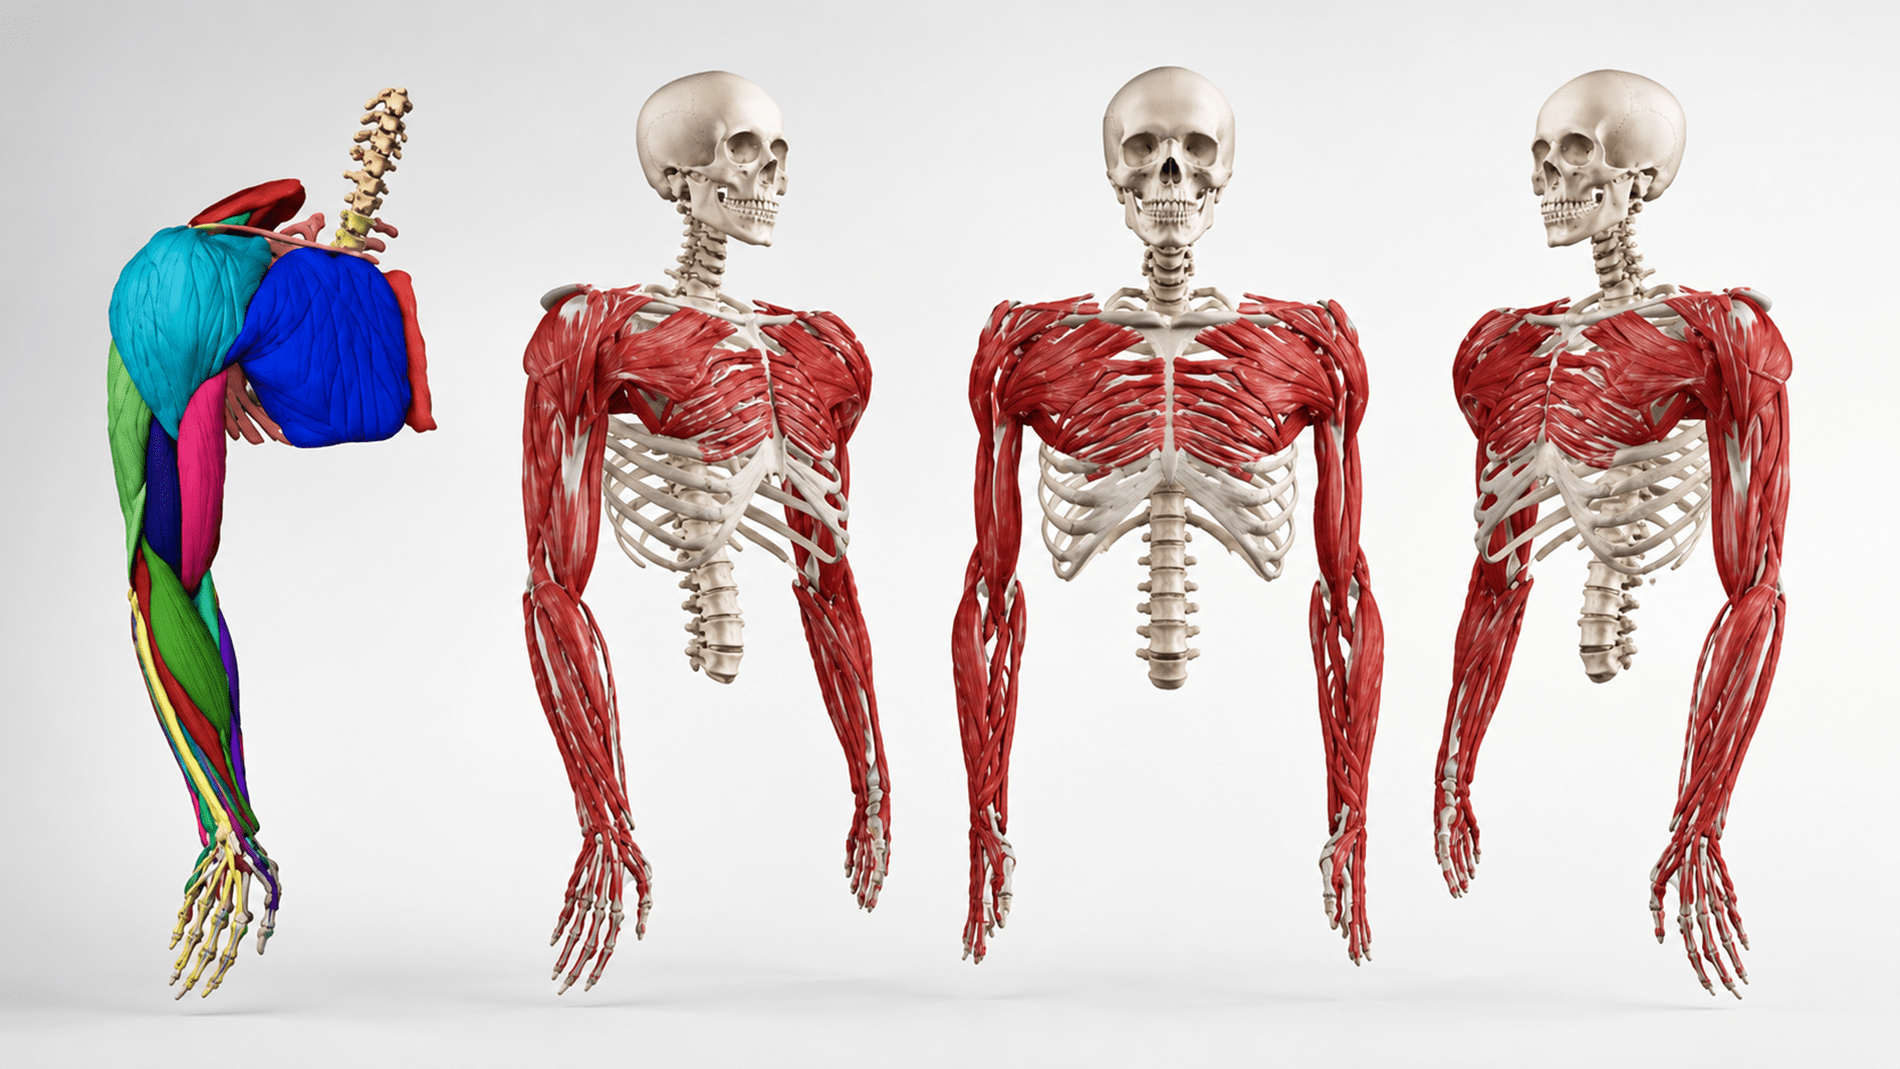
How did he do it? First, he studied how muscle fibers work in the human arm. He then used MRI to collect 3D images of the arm’s muscles in many different positions, producing more than one terabyte of data. From this data, he built a computer model of the arm that simulated the contraction of muscle fibers as the arm moved. The model used efficient algorithms from robotics to predict muscle forces in real time. This was Toki’s undergraduate research.
In a separate use of the MRI machine, he used fMRI to scan brain signals as a subject moved his arms. The goal was to find a correlation between brain signals and muscle activity, in other words, to understand how the brain controls the muscles. This is where the muscle model came in. Because there is no way to record brain signals and muscle activity at the same time inside an MRI machine, a position and force sensor was attached to the subject’s hand, and the model predicted muscle activity from those position and force readings.
Understanding how the brain controls muscles could have a significant impact on neurological surgery, musculoskeletal surgery and physical rehabilitation. And because the muscle model is compatible with robotics algorithms, it could also be built into robotic exoskeletons or personal robot assistants that need to work closely with people.
As a child, Toki loved building with LEGO bricks, and the bigger the construction, the better. He also liked taking apart old electronics to see how they worked and then putting them back together again. But he was not entirely left-brained. He also spent a few hours every day practicing the piano, and by early high school he had earned the highest certificates of merit for his playing. Writing software came much later, not until his freshman year at Stanford.
As an undergraduate majoring in computer science, he found the most challenging part to be the rigorous pace of the Stanford curriculum. The hours of studying and homework were overwhelming. He slept about six hours a night on average, and sometimes only four when he chose to play the piano to take his mind off his studies.
What subjects matter most when it comes to building a robotic arm? Toki believes that advanced mathematics is essential for developing the algorithms, and that a deep knowledge of physics is needed to build the robot itself.
Toki spent the summer of 2018 as an intern in Nissan’s autonomous driving division. Now he wants to focus more on AI in his graduate studies. His goal is to develop better algorithms that help robots interact with the physical world, and he hopes one day to build a smart robot that can handle many of the tasks in our daily lives. “Wouldn’t it be nice if a robot could wash the dishes or clean the house one day?” Toki asked with a smile.